Welcome to the Intelligent Design and Robotics Lab (IDR Lab). We develop intelligent computational methods for engineering design — spanning generative design, CAD/CAE, mechanism synthesis, robotics, mixed reality simulation, embodied AI, physical AI, and theoretical kinematics — and we also build, prototype, and physically validate the mechanisms and robots we design, from AI-driven mechanism and robot design and autonomous manipulation to mixed reality teleoperation and the design, manufacturing, and control of soft and compliant robotic systems. Learn more on our Research and Publications pages, or watch lab demos on our YouTube channel.
Research Videos
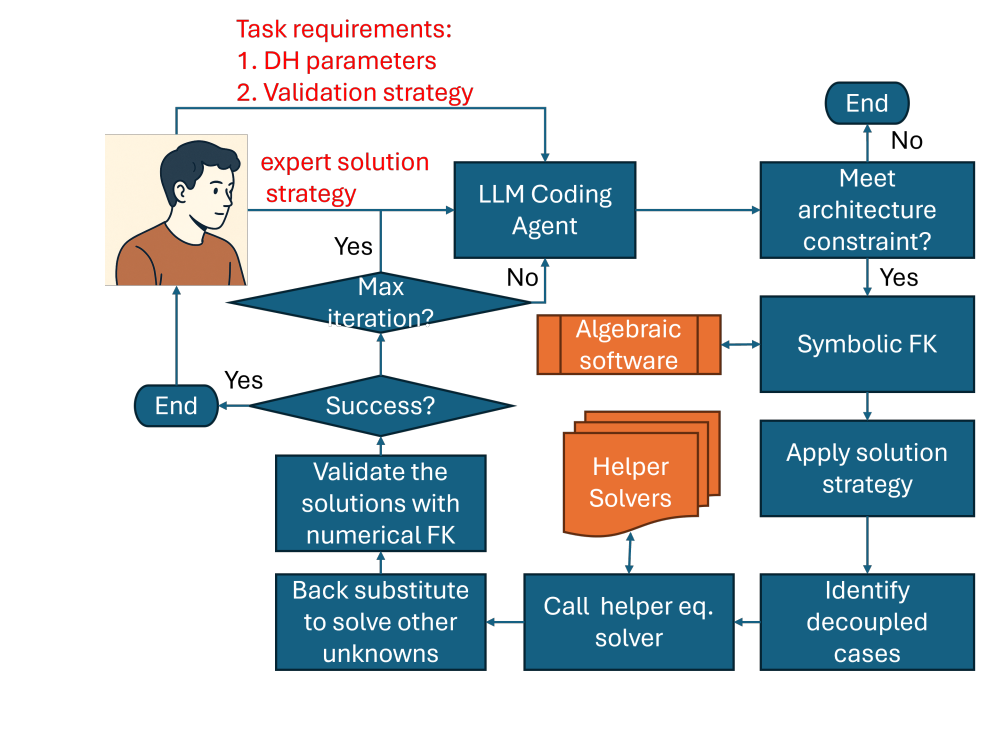
Solving Kinematics Problems by Leveraging the Power of Large Language Models
From Screw Theory to Compliant Mechanisms: Summer Screws 2026 Keynote
The Use of AI in Kinematics: MSR 2026 Tutorial
Large Language Model Assisted Development of Analytical Inverse Kinematics Solvers for Robots
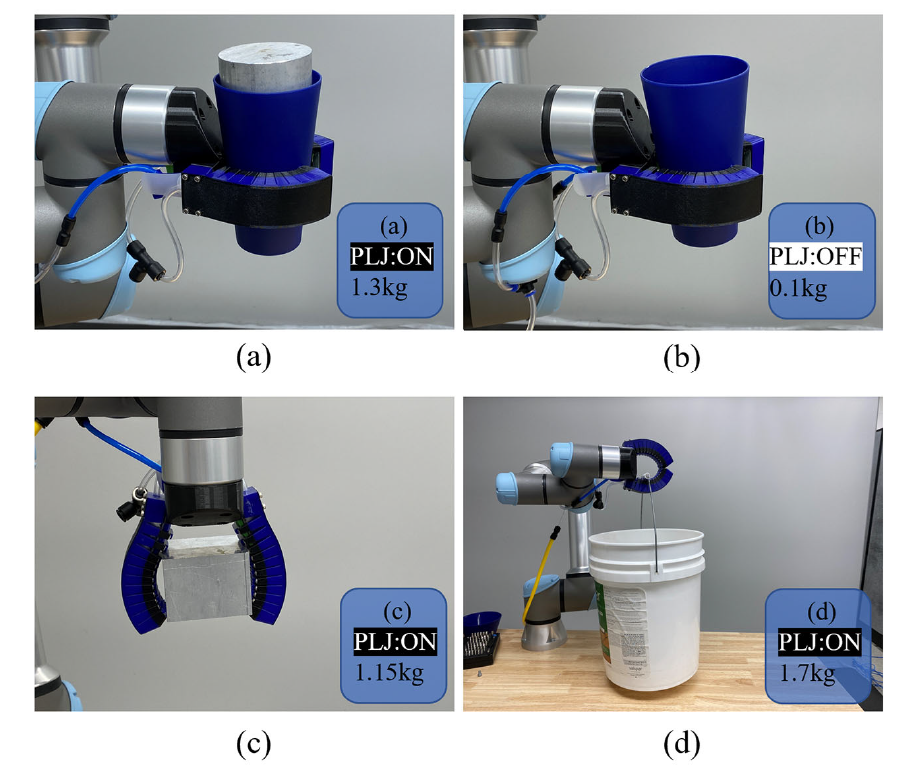
A 3D Printed Soft Robotic Gripper with a Variable Stiffness Enabled by Layer Jamming Technology
A High Performance Pneumatically Actuated Soft Gripper Based on Layer Jamming
Research Highlights
News
- 2026/08 Dr. Haijun Su received the 2026 ASME DED Mechanisms and Robotics Award.
- 2026/08 Dr. Haijun Su received the 2026 ASME DED Leonardo Da Vinci Award, presented at the 2026 ASME IDETC/CIE conference held in Houston, Texas.
- 2026/08 Our paper “Solving Kinematics Problems by Leveraging the Power of Large Language Models” received the 2026 ASME Mechanisms and Robotics Conference Best Paper Award.
- 2026/07/22 Hai-Jun Su delivered the invited keynote “From Screw Theory to Compliant Mechanisms: A Unified Framework for Mobility Analysis and Synthesis” at IFToMM Summer Screws 2026.
- 2026/05 Hai-Jun Su gave the tutorial “The Use of AI in Kinematics” at MSR 2026 in Irvine, CA.
- 2026/05 Hai-Jun Su presented “Large Language Model Assisted Human-AI Collaborative Development of Analytical Inverse Kinematics Solvers for Robot Manipulators” at MSR 2026 in Irvine, CA.
- 2026/04/10 Jessica Sillus successfully defended her M.S. thesis titled “Design, Simulation, and Manufacturing of a Tendon Driven Compliant Robotic Gripper With 3D Printed Force Sensing Capabilities for Space Applications.”
- 2026/04/07 Quill van Roodselaar successfully defended her undergraduate thesis titled “Design and Analysis of a Precise Linkage-Driven Robotic Hand for Manufacturing Applications.”
- 2026/02 Our paper “Large Language Model Assisted Human-AI Collaborative Development of Analytical Inverse Kinematics Solvers for Robot Manipulators” was accepted to Mechanism and Machine Theory.